
www.agritechmag.com
12
'26
Written on Modified on
PC-Based Control Enables Fleet-Scale Autonomous Greenhouse Harvesting
Four Growers integrated Beckhoff PC-based control and EtherCAT communication into its autonomous robotic harvester to achieve certifiable safety and scalable commercial deployment.
www.beckhoff.com
Application Area: Autonomous Agricultural Robotics and Embedded Control Systems
Industry Sector: Commercial Greenhouse Agriculture
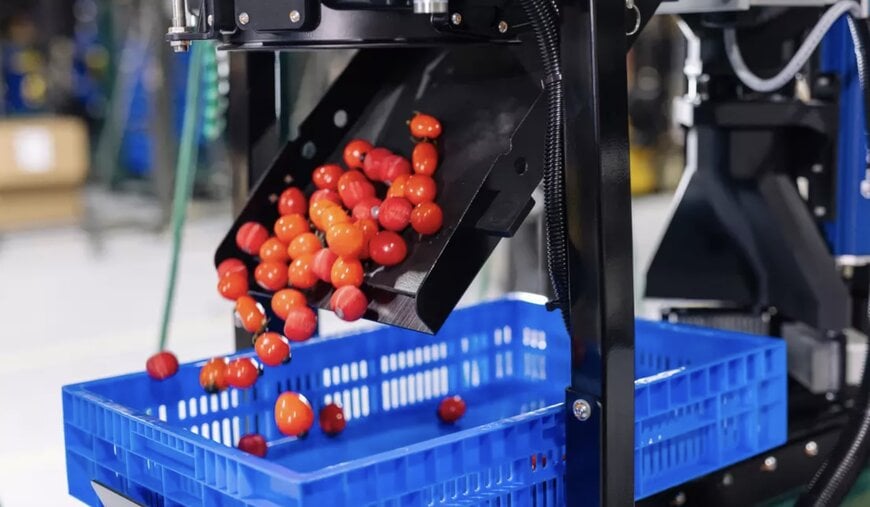
Commercial greenhouse operators face persistent labor shortages alongside stringent demands for consistent, damage-free harvesting of delicate crops such as on-the-vine tomatoes. Pittsburgh-based robotics manufacturer Four Growers developed the GR-200 autonomous harvesting system to automate picking and crate handling along existing greenhouse irrigation pipe rails. Transitioning from early prototypes to fleet-scale series production across North America and Europe required overcoming severe spatial constraints, high ambient humidity, strict international functional safety certifications, and deterministic motion synchronization across dual harvesting and packing carts.
Consolidated Embedded Control and Deterministic Motion
To eliminate sprawling external control cabinets and multi-controller complexity, Four Growers consolidated sequence control, safety logic, and six-axis motion onto a single Beckhoff CX5230 Embedded PC running TwinCAT automation software on a TwinCAT/BSD operating system. Real-time EtherCAT communication synchronizes target coordinates from an external image processing system with vacuum suction actuation, robotic arm kinematics, and automated crate shuffling.
Compact ELM7231-9018 EtherCAT servomotor terminals pair with AM8100 servomotors utilizing One Cable Technology (OCT), merging power and feedback signals into a single conductor. This space-saving architecture mounts directly onto the robot’s backplate, lowering power consumption, minimizing heat dissipation, and eliminating vulnerable external wiring harnesses within narrow greenhouse aisles. Modular EtherCAT I/O terminals and an EL6224 IO-Link master enable plug-and-play integration of RTD thermal sensors, brake choppers, and field actuators.
Integrated Functional Safety Across Dual-Cart Platforms
Operating autonomous mobile robots alongside human workers in tight aisles requires deterministic obstacle response and certifiable safety compliance. Engineers implemented TwinSAFE logic and Functional Safety over EtherCAT (FSoE) to transmit emergency-stop signals and safety laser scanner states directly across the standard EtherCAT network between the harvesting and packing carts.
“One of the biggest technical demands is reliability. All the GR-200 components, movement, suction, crate shuffling, must work together smoothly, especially in hot and humid environments,” explained Peter Beauregard, Senior Electrical Engineer at Four Growers. Pre-certified safety function blocks streamlined validation to regional regulatory standards while eliminating redundant safety hardwiring.
Scalable Fleet Deployment and Harvesting Performance
Standardizing on the unified TwinCAT environment, automatic hardware scanning, and integrated project comparison tools accelerated software iteration and fleet commissioning. In operational testing, the vacuum-assisted harvesting system achieved peak picking cycle speeds of 2.79 seconds per tomato without bruising fruit. By consolidating multi-axis motion, diagnostics, and functional safety into a compact embedded footprint, Four Growers reduced mechanical failure points and established a scalable automation foundation for commercial greenhouse fleets.
Edited by Romila DSilva, Induportals Editor, with AI assistance.
www.beckhoff.com
